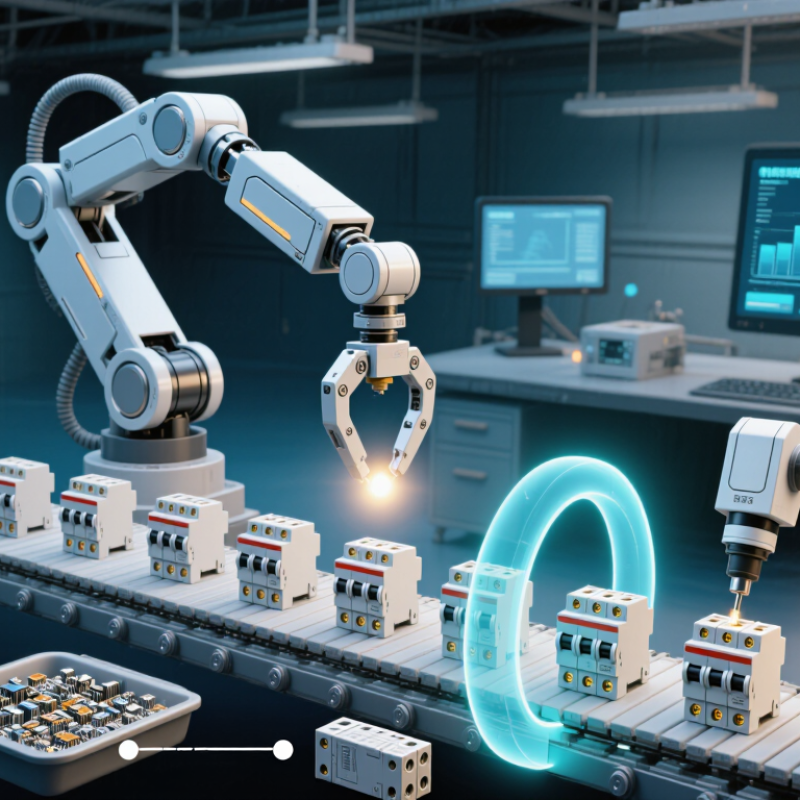
An Mcb Assembly Robot is an automated production system designed to build miniature circuit breakers with repeatable speed and accuracy. It handles tasks such as component feeding, contact installation, screw fastening, arc-chamber placement, and functional inspection. In a typical line, vibratory feeders separate small parts before robotic grippers position them inside molded cases. Vision cameras check orientation, while torque-controlled drivers tighten screws to defined settings. Every movement matters.
The process resembles a carefully coordinated workshop, but with fewer human hands. Sensors confirm whether springs, terminals, and trip mechanisms are correctly placed. A programmable controller then guides each station through its assigned sequence. Electrical testers may verify insulation, continuity, and trip performance before the finished breaker enters packaging. Data records can connect test results with a batch or production time, supporting quality audits and maintenance decisions.
Still, automation is not infallible. A misaligned feeder, worn gripper, or poorly calibrated sensor can create defects that look minor at first. Experienced engineers therefore combine machine data with physical checks and regular preventive maintenance. The robot improves consistency, but it does not replace professional judgment. Its reliability depends on sound design, suitable components, controlled operating conditions, and verified safety procedures. Understanding how an Mcb Assembly Robot works helps manufacturers evaluate productivity without ignoring risks, limitations, or the human expertise behind dependable circuit-breaker production.
An MCB assembly robot is an automated system that helps build miniature circuit breakers by positioning and joining their components. MCBs protect electrical circuits by interrupting current during overloads or short circuits. The robot’s purpose is to make assembly more consistent, especially when small parts must fit together with controlled pressure and alignment.
A typical system may use feeders to present parts, grippers to hold them, and sensors to check their position. The robot can place contacts, springs, and other components into a breaker housing, then pass the unit to fastening or inspection stations. A camera might detect a missing part, while a force sensor can flag an unusually tight fit. Small details matter. A misaligned spring can affect how the mechanism moves.
The robot does not guarantee a reliable breaker on its own. Tool wear, part variation, and poorly adjusted settings can still cause defects, so production teams need routine checks and sample testing. Automation helps repeat a process; it does not replace engineering judgment. And the setup is never quite perfect.
An MCB assembly robot is an automated cell that places and joins miniature circuit breaker components. Its architecture links mechanical handling, electrical control, sensing, and quality checks. A typical cell includes a parts feeder, robot arm, gripper, assembly fixtures, controller, and safety enclosure. Each part has a defined position and orientation before assembly begins. Small differences matter.
The controller coordinates each step, from picking a contact or spring to positioning it in the breaker housing. Sensors confirm part presence and alignment. A camera may check orientation, while force monitoring can flag a part that does not seat correctly. The robot then transfers the partly assembled unit to the next station, such as fastening or testing. In practice, the exact layout depends on the breaker design and required production rate. A sensor can miss a subtle defect, so inspection settings need regular review.
Tips: Keep feeder tracks clean and verify gripper alignment during setup. Test the system with representative parts, including normal variations. Record rejected units and recurring stoppages; these details often reveal a weak fixture or an inconsistent feed. Automation helps, but it is not perfect. Human review remains useful when faults repeat or measurements drift.
An MCB assembly robot is an automated system that builds miniature circuit breakers with controlled speed and repeatable accuracy. It handles small parts, including housings, contacts, springs, terminals, and trip mechanisms. The process begins with component feeding. Vibratory bowls or precision feeders orient each part before robotic grippers collect it. Incorrectly positioned components are rejected instead of forced into place.
The robot then places the internal mechanism into the molded housing. It fits the moving contact, spring, thermal element, and magnetic trip unit in a defined sequence. Servo-driven tools apply measured pressure during insertion. Another station installs the cover and secures it with screws, clips, or heat-staked joints. Torque sensors help prevent loose connections and damaged plastic. Small details matter here.
After assembly, cameras inspect alignment, surface defects, and missing components. The system checks contact movement and verifies that the operating handle travels correctly. Electrical testers may measure continuity, insulation resistance, and trip performance under controlled conditions. Results are recorded for traceability, allowing technicians to locate process changes or faulty batches. Human oversight remains important. A sensor can misread a reflective metal surface, and software settings may need adjustment after tooling changes. No production line is perfect. Careful maintenance, sample testing, and operator review help keep the assembly reliable.
An MCB assembly robot coordinates part feeding, mechanism installation, terminal assembly, housing closure, and quality testing. The chart shows representative processing times for one miniature circuit breaker during a step-by-step automated assembly cycle.
Processing times are typical engineering reference values for automated MCB assembly. Actual times vary according to product design, robot configuration, feeding method, and inspection requirements.
What Is an MCB Assembly Robot and How Does It Work?
An MCB assembly robot is an automated cell for assembling miniature circuit breakers. It handles small parts with steady speed and repeatable force. Operators load molded cases, terminals, springs, and switches into separate feeders. The robot selects each part and places it in a fixed sequence. Vision cameras check orientation before assembly begins. A misplaced spring can stop the entire process.
Automation technologies improve both productivity and consistency. Servo-driven tools control insertion depth and fastening torque. Sensors confirm whether each component reaches its required position. The system can also record cycle time, torque values, and inspection results. These records support traceability during production audits. Quality control starts during assembly, not only at the final station. Electrical testers verify contact resistance, insulation performance, and trip response. A reject chute removes units that fail inspection.
No system is perfect.
Dust may affect a camera lens. Worn grippers can create hidden alignment problems. For this reason, technicians should calibrate sensors, inspect tooling, and review error patterns regularly. Sampling tests remain useful, even when every unit receives automated inspection. A robot may detect a dimensional fault but miss a weak material surface. Human experience still matters when unusual defects appear. In practice, the strongest MCB lines combine robotic precision, documented procedures, and careful operator judgment.
An MCB assembly robot is part of an automated production system that handles, positions, or assembles components for miniature circuit breakers (MCBs). A typical line combines robots with feeders, fixtures, sensors, screwdrivers, and inspection equipment. The sequence and checks vary by product design and manufacturer.
| Production stage | Automation technology | What happens | Typical quality control |
|---|---|---|---|
| Component feeding | Hoppers, vibratory feeders, conveyors, and presence sensors | Components such as molded housings, contacts, springs, and operating parts are supplied to the assembly stations in a controlled orientation. | Sensors check that parts are available; vision systems may verify orientation or detect visibly incorrect parts. |
| Part picking and positioning | Pick-and-place robot, gripper, and machine vision | The robot picks selected parts and places them into a fixture or directly into the breaker housing. | Position checks confirm that a part is present and seated before the next operation begins. |
| Internal mechanism assembly | Robotic handling, guided insertion tools, and assembly fixtures | The mechanism and related components are assembled in the arrangement specified by the product design. | Presence, position, and sequence checks help identify missing or incorrectly placed components. |
| Screw fastening or joining | Automatic screwdrivers or other design-appropriate joining equipment | Fasteners or other specified joining features secure the assembly. The method depends on the breaker construction. | For screw fastening, the station can monitor parameters such as torque and angle and flag results outside configured limits. |
| Cover closure and marking | Pressing or closure station, label applicator, and code marking equipment | The housing is closed and required identification or traceability information is applied. | Checks may verify closure, label presence, and whether printed or marked information is readable. |
| Electrical and mechanical testing | Automated test fixtures and measurement instruments | Depending on the product and test plan, completed units may undergo checks such as continuity, dielectric withstand, or operating-mechanism tests. | Results are compared with product-specific acceptance criteria; failed units can be rejected or routed for review. |
| Sorting and traceability | Programmable logic controller (PLC), reject gate, and production data system | The control system coordinates station steps and directs completed products to the appropriate output path. | Production records can associate test results and station status with a batch or product identifier, where traceability is implemented. |
Quality checks, test methods, and acceptance limits are product-specific and should be defined by the applicable design requirements and safety standards.
An MCB assembly robot builds miniature circuit breakers through programmed, repeatable movements. It can pick housings, position terminals, insert springs, tighten screws, and check labels. Vision cameras inspect alignment before each unit leaves the station. Torque sensors help prevent loose or over-tightened connections. In a busy electrical equipment plant, this process can maintain steady output across long shifts. Small bins, feeders, and conveyors keep components moving in a controlled sequence.
The main benefit is consistency. A robot applies similar force to every screw and places parts at nearly identical positions. This reduces assembly variation and supports clearer quality records. Operators can monitor production data, refill feeders, and handle inspection tasks instead of repeating tiring motions. The system also helps reduce hand injuries caused by repetitive fastening work. However, speed alone does not guarantee quality. Poorly calibrated sensors can repeat the same mistake hundreds of times.
Operational limitations deserve close attention. MCB designs may change, and each change can require new grippers, programs, or testing fixtures. Tiny springs may tilt inside feeders, especially when surfaces become dusty. A robot also struggles with unusual parts that an experienced technician can recognize immediately. Maintenance teams need practical training in mechanics, controls, and electrical safety. Initial investment can be substantial, particularly for low-volume production. Human checks remain necessary for process validation, fault investigation, and decisions involving uncertain defects. Automation is powerful, but not self-sufficient.
| Cookie | Duration | Description |
|---|---|---|
| AWSALB | 7 days | AWSALB is a cookie generated by the Application load balancer in the Amazon Web Services. It works slightly different from AWSELB. |
| AWSALBCORS | 7 days | This cookie is used for load balancing services provded by Amazon inorder to optimize the user experience. Amazon has updated the ALB and CLB so that customers can continue to use the CORS request with stickness. |
| cookielawinfo-checkbox-advertisement | 1 year | The cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Advertisement". |
| cookielawinfo-checkbox-analytics | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Analytic / Performance". |
| cookielawinfo-checkbox-functional | 11 months | The cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Functional". |
| cookielawinfo-checkbox-necessary | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookies is used to store the user consent for the cookies in the category "Strictly Necessary". |
| cookielawinfo-checkbox-performance | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Performance". |
| cookielawinfo-checkbox-preferences | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Preferences." |
| elementor | never | This cookie is used by the website's WordPress theme. It allows the website owner to implement or change the website's content in real-time. |
| viewed_cookie_policy | 11 months | The cookie is set by the GDPR Cookie Consent plugin and is used to store whether or not user has consented to the use of cookies. It does not store any personal data. |
| Cookie | Duration | Description |
|---|---|---|
| CONSENT | 16 years 4 months | These cookies are set via embedded youtube-videos. They register anonymous statistical data on for example how many times the video is displayed and what settings are used for playback.No sensitive data is collected unless you log in to your google account, in that case your choices are linked with your account, for example if you click “like” on a video. |
| _ga | 2 years | This cookie is installed by Google Analytics. The cookie is used to calculate visitor, session, campaign data and keep track of site usage for the site's analytics report. The cookies store information anonymously and assign a randomly generated number to identify unique visitors. |
| _gat_gtag_UA_47200144_1 | 1 minute | This cookie is set by Google and is used to distinguish users. |
| _gid | 1 day | This cookie is installed by Google Analytics. The cookie is used to store information of how visitors use a website and helps in creating an analytics report of how the website is doing. The data collected including the number visitors, the source where they have come from, and the pages visted in an anonymous form. |
| _hjAbsoluteSessionInProgress | session | This cookie is used to count how many times a website has been visited by different visitors. This is done by assigning the visitor an ID, so the visitor does not get registered twice. |
| _hjFirstSeen | 30 minutes | This is set by Hotjar to identify a new user’s first session. It stores a true/false value, indicating whether this was the first time Hotjar saw this user. It is used by Recording filters to identify new user sessions. |
| _hjid | 1 year | This cookie is set by Hotjar. This cookie is set when the customer first lands on a page with the Hotjar script. It is used to persist the random user ID, unique to that site on the browser. This ensures that behavior in subsequent visits to the same site will be attributed to the same user ID. |
| _hjIncludedInPageviewSample | session | This cookie is used to detect whether the user navigation and interactions are included in the website’s data analytics. |
| Cookie | Duration | Description |
|---|---|---|
| IDE | 1 year 24 days | This cookie is used by Google DoubleClick and stores information about how the user uses the website and any other advertisement before visiting the website. This is used to present users with ads that are relevant to them according to the user profile. |
| NID | 6 months | This cookie is used to a profile based on user's interest and display personalized ads to the users. |
| test_cookie | 15 minutes | This cookie is set by doubleclick.net. The purpose of the cookie is to determine if the user's browser supports cookies. |
| VISITOR_INFO1_LIVE | 5 months 27 days | This cookie is set by Youtube it is used to track the information of the embedded YouTube videos on a website. |
| YSC | session | This cookies is set by Youtube and is used to track the views of embedded videos. |
| yt-remote-connected-devices | never | These cookies are set via embedded youtube-videos. |
| yt-remote-device-id | never | These cookies are set via embedded youtube-videos. |
| Cookie | Duration | Description |
|---|---|---|
| qtrans_front_language | 1 year | This cookie is set by qTranslate WordPress plugin. The cookie is used to manage the preferred language of the visitor. |